
01
Resilience audits
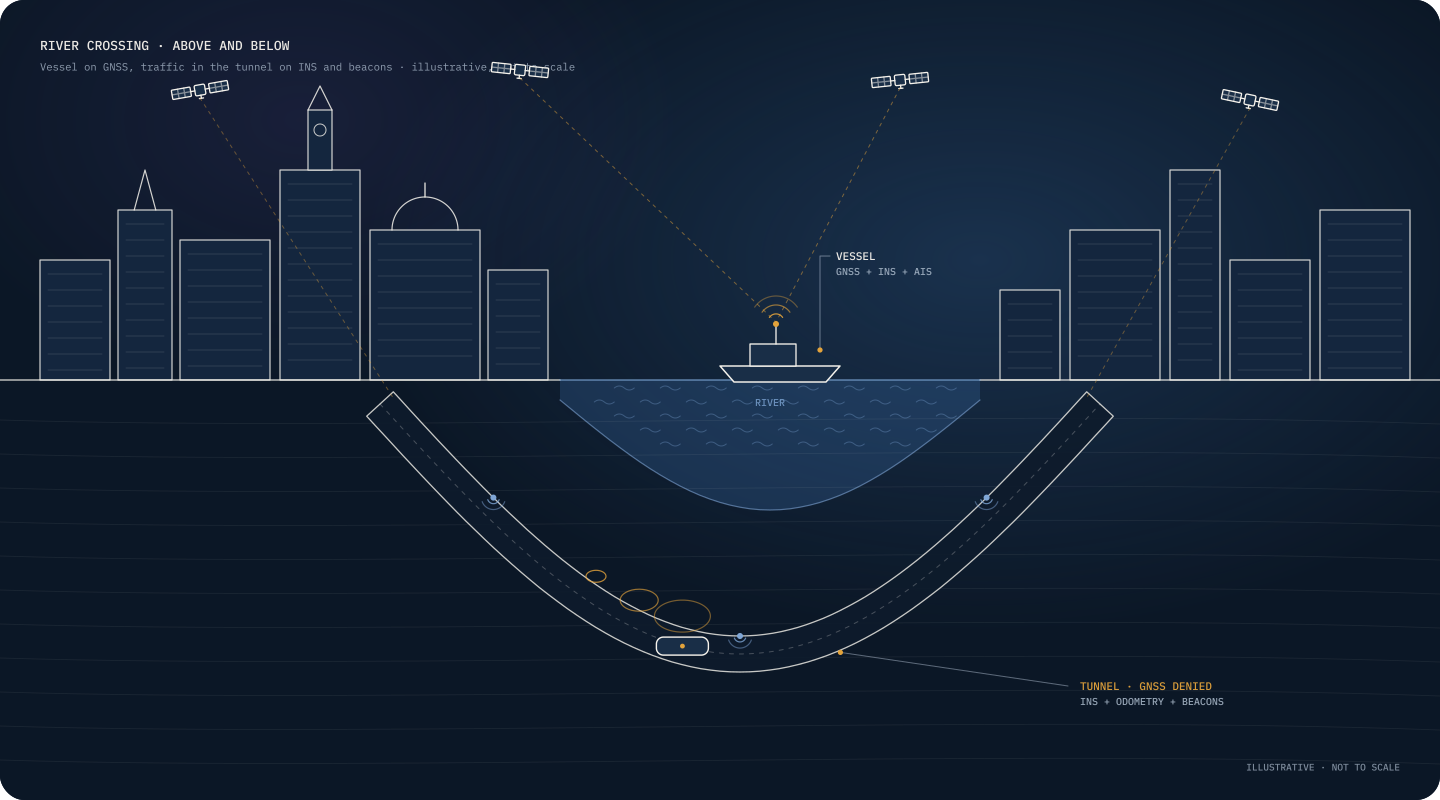
What happens to your system when GPS is jammed, spoofed or simply missing.
About
Bearing & Fix is run by Dan Chadwick, a PhD researcher and software developer working on navigation without GNSS: particle filters, magnetic map matching and heading from polarised light. We bring that work to companies outside the lab.

Live demo · Particle filter · Illustrative
Eryri · OS Terrain 50
Contains OS data © Crown copyright and database right 2026
What we do
Three kinds of work, each with a clear scope and a fixed price.
What happens to your system when GPS is jammed, spoofed or simply missing.
Kalman and particle filters, IMU calibration and multi-sensor fusion.
Independent simulation and test campaigns with honest statistics.
Background
{Year} — now
{One or two sentences on your research: particle filters, magnetic map matching, polarised-light heading.}
{Year} — now
{Where and what you build. Web, data, embedded?}
{Year}
Consulting on GNSS resilience, sensor fusion and navigation testing.
{Year}
{Short description.}
Research interests
How we work
Clear scope and a price agreed by email before any work starts. No surprises.
No sales calls needed. Send a short brief and get a quote within two working days.
Results reported with uncertainty and the conditions they hold under, not just best cases.
Publications
{Authors} · {Venue}, {Year}
{Authors} · {Venue}, {Year}
{Authors} · {Venue}, {Year}
Send a short brief and we’ll reply within two working days.
dan@bearingandfix.co.uk