
Filters · 10 min read
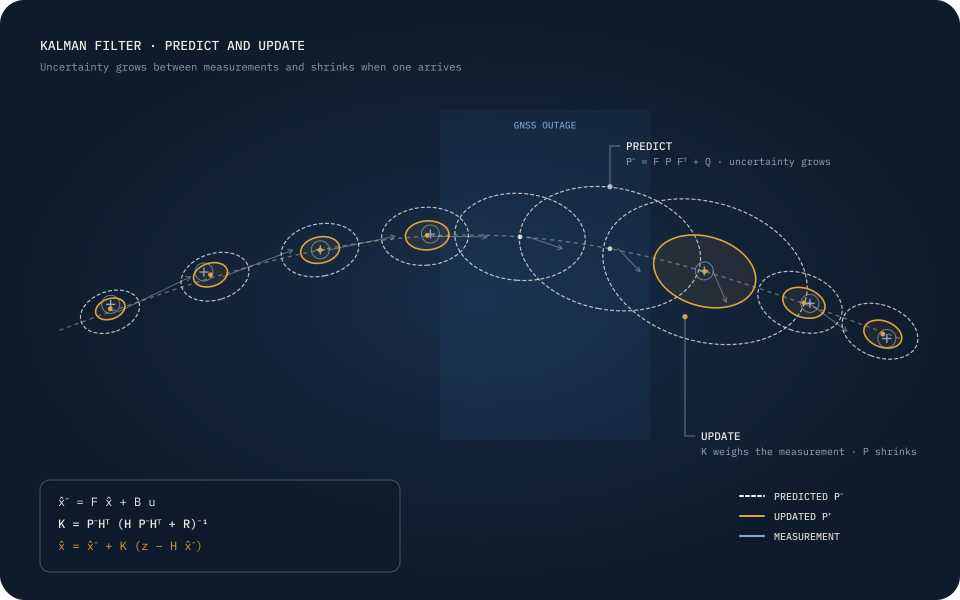
Kalman vs particle filters: when to use which
A practical guide, with code, to choosing the right estimator.
Coming soon
Navigation notes
Plain-English notes on GNSS, sensor fusion and estimation, from someone who works on it every day.
Featured · GNSS · 7 min read
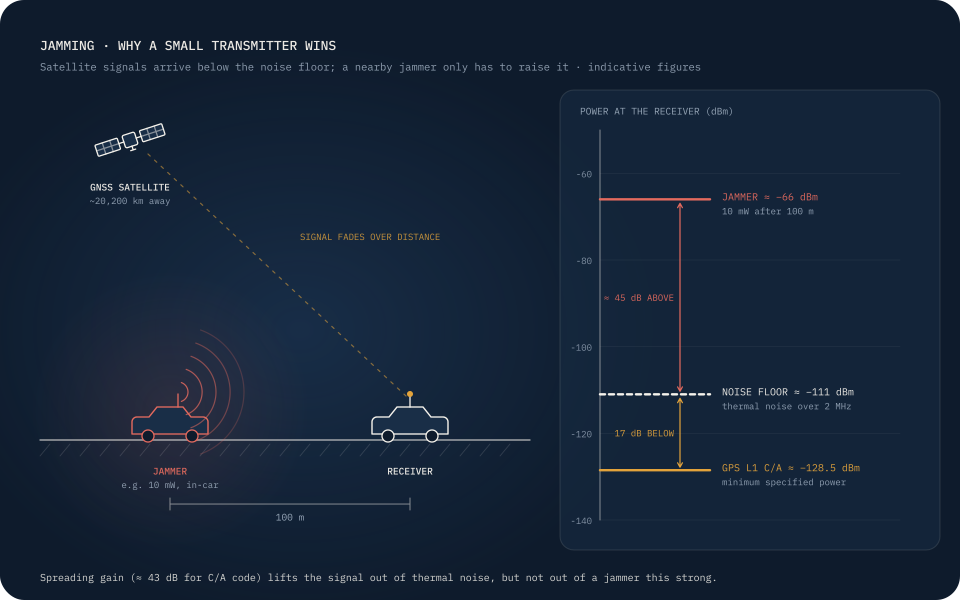
Why a cheap transmitter can drown out satellites 20,000 km away, what that looks like to a receiver, and what you can do about it.
Filters · 10 min read
A practical guide, with code, to choosing the right estimator.
Coming soon
Checklist · 5 min read
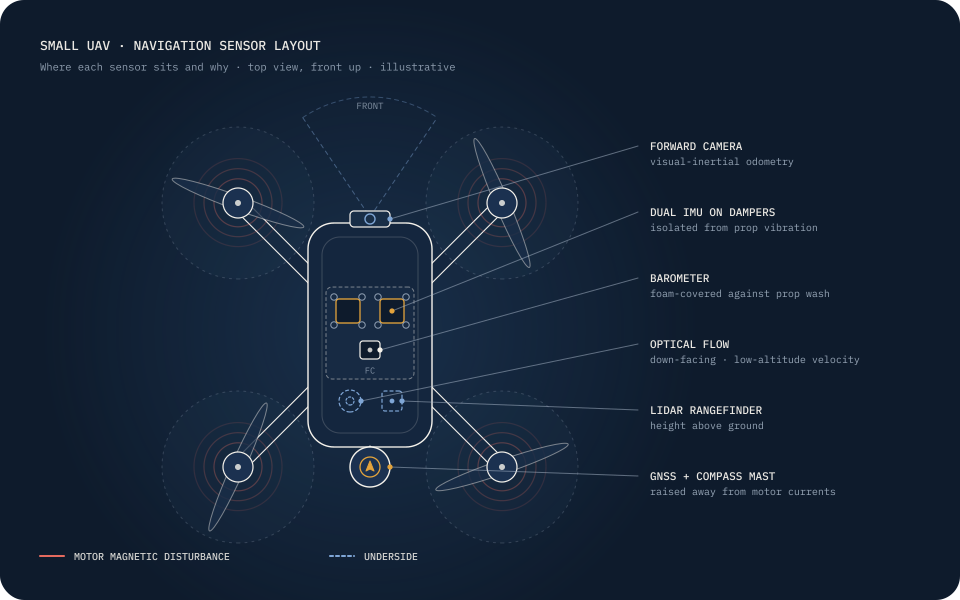
Twelve questions to ask before you fly somewhere GPS can’t be trusted.
Coming soon
Inertial · 8 min read
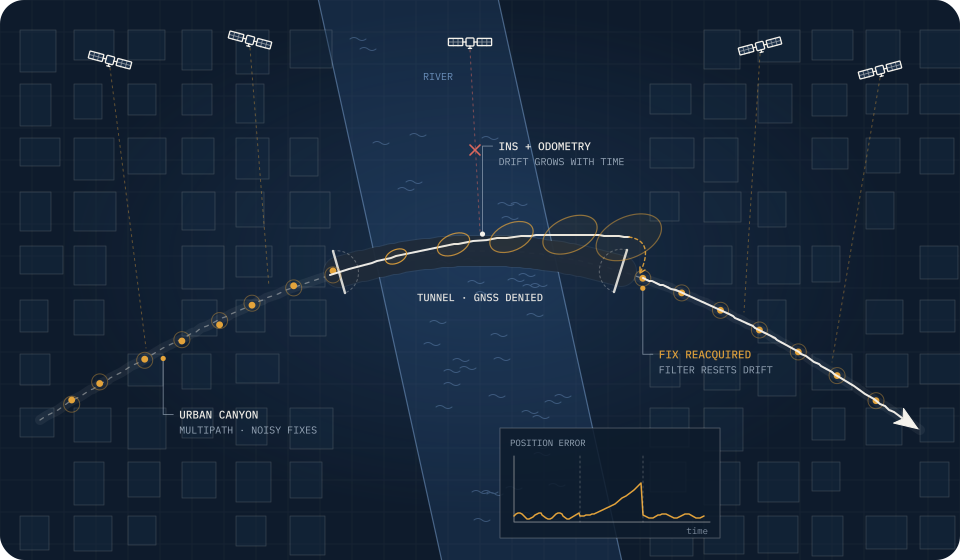
Why small sensor errors grow into big position errors, and how to slow them down.
Coming soon
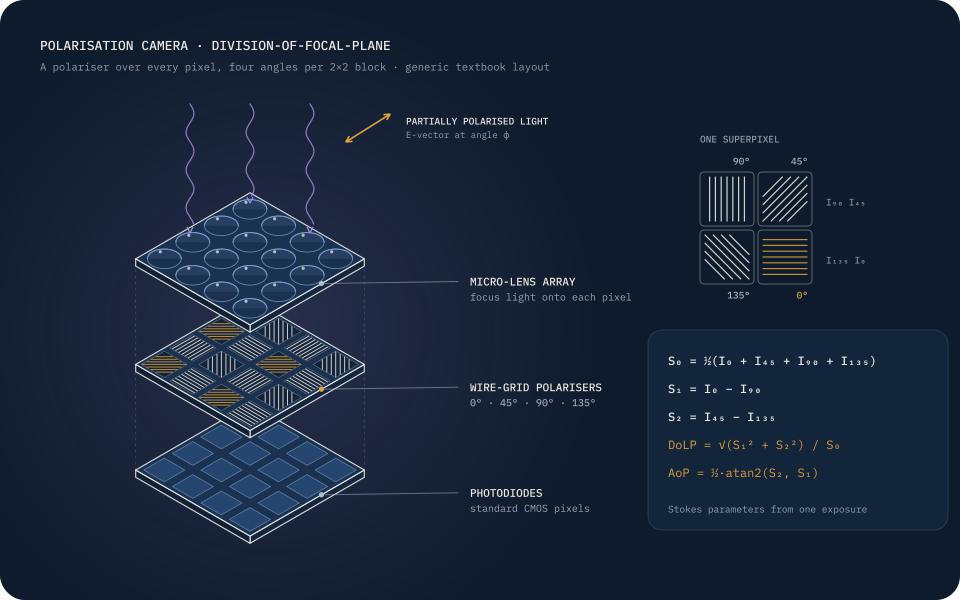
Polarisation · 6 min read
The compass bees use, and how cameras can borrow it.
Coming soon
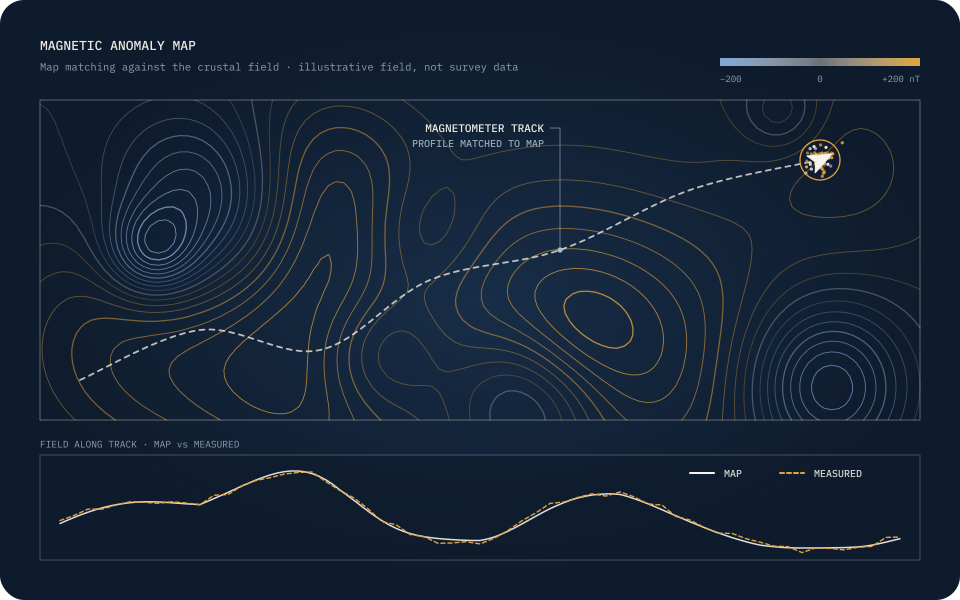
Magnetics · 9 min read
How magnetic anomaly maps can stand in for satellites.
Coming soon
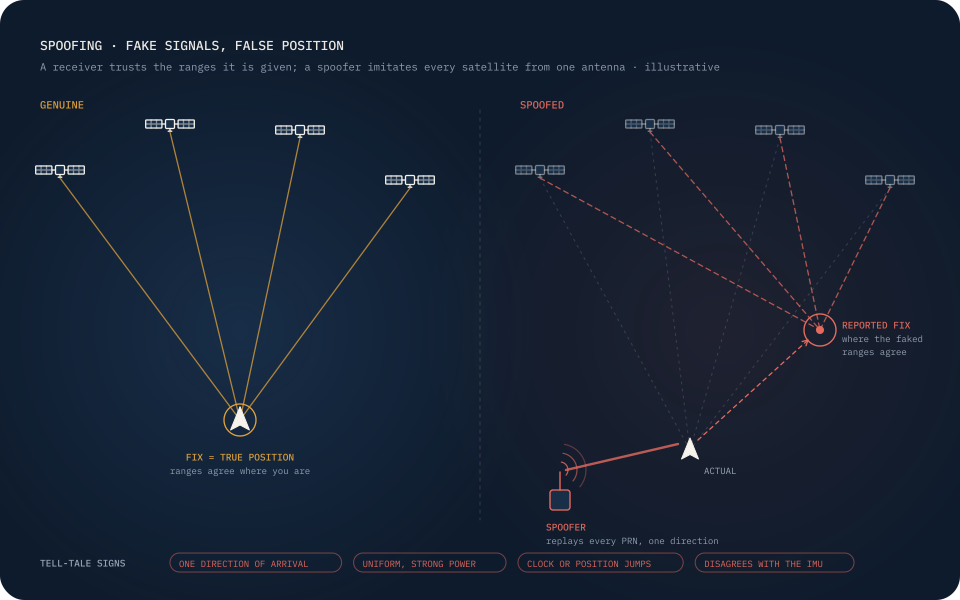
Spoofing · 7 min read
Fake signals, a false position, and the signs that give it away.
Coming soon
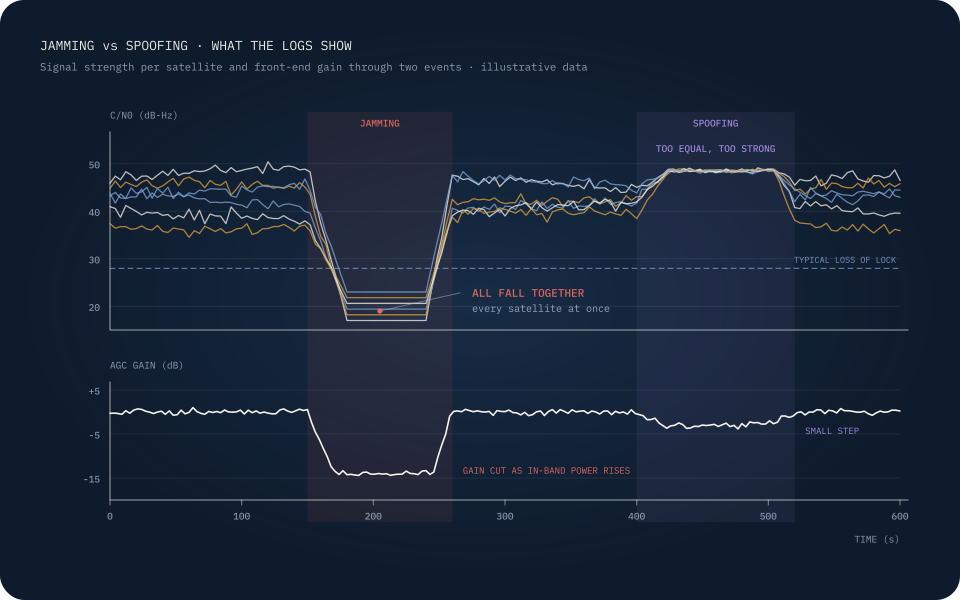
Interference · 8 min read
The C/N0 and gain patterns that tell the two apart.
Coming soon
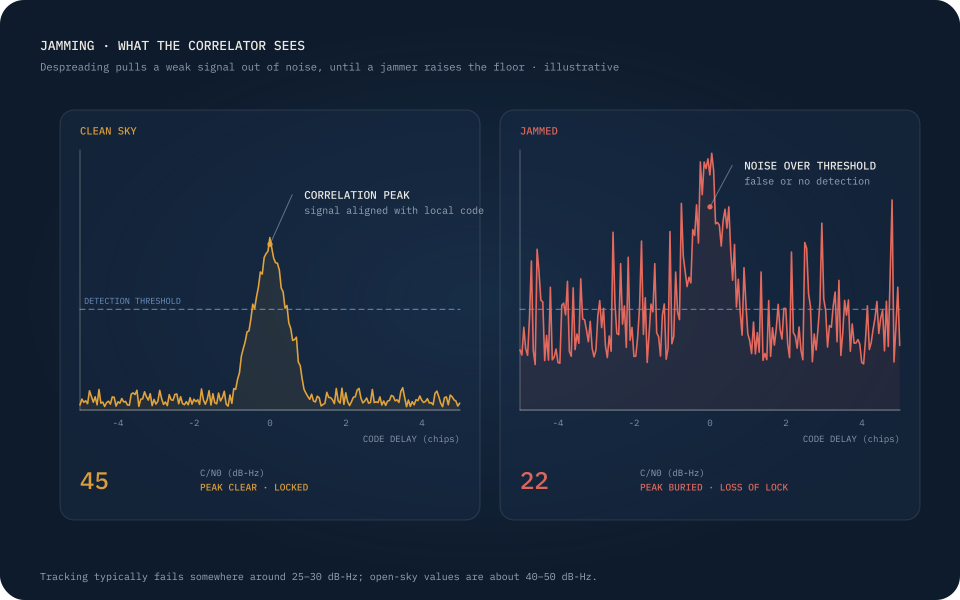
Jamming · 6 min read
Why a weak signal survives noise, but not a transmitter nearby.
Coming soon
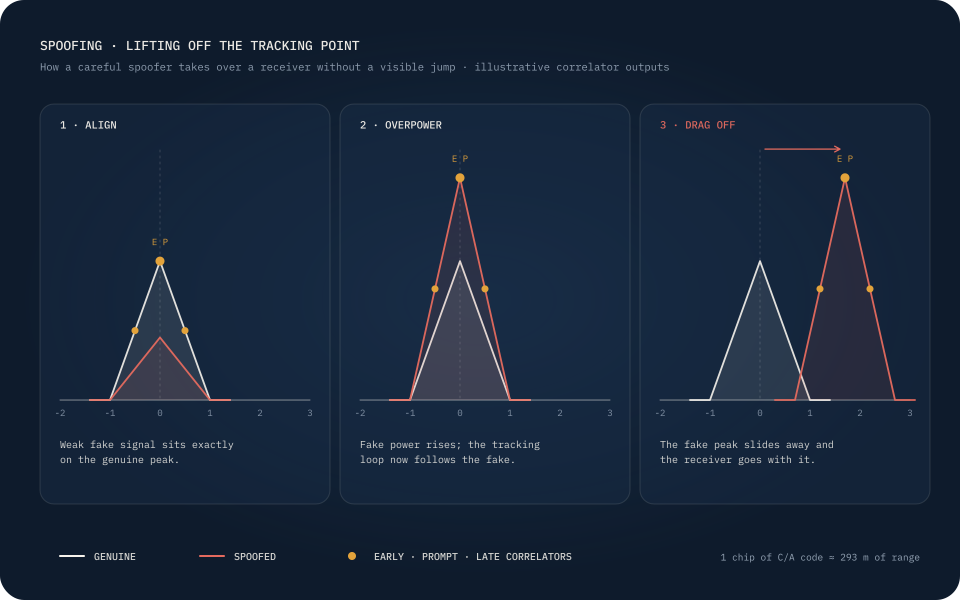
Spoofing · 6 min read
How a careful spoofer lifts off the tracking point.
Coming soon
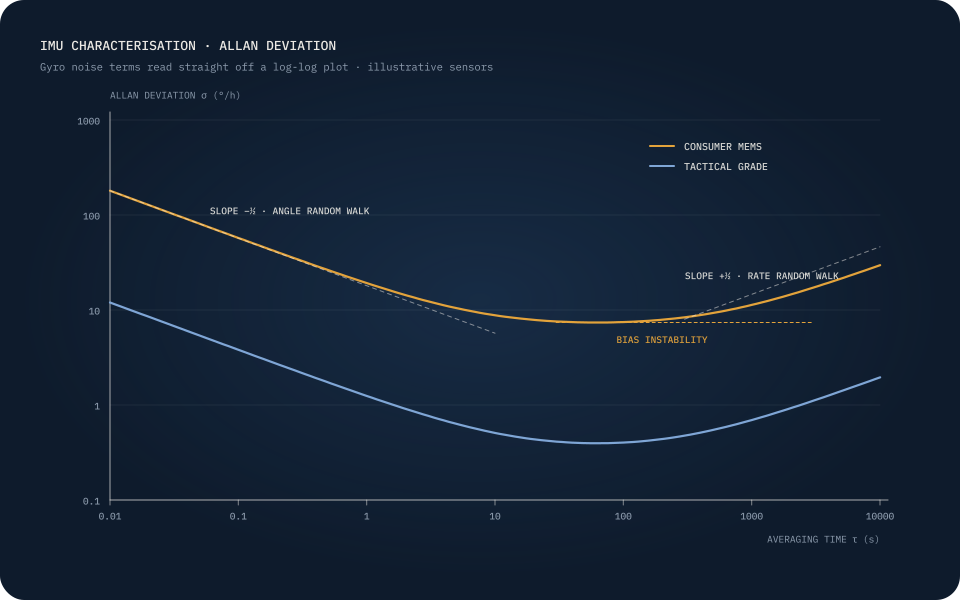
Inertial · 7 min read
The noise terms you can read straight off a log-log chart.
Coming soon
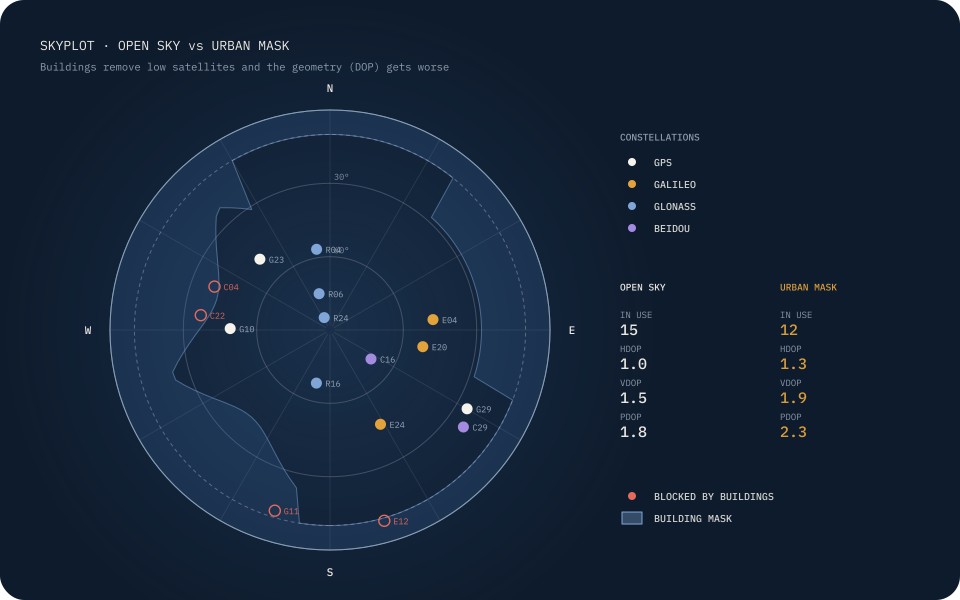
GNSS · 5 min read
Why the same receiver does worse between tall buildings.
Coming soon
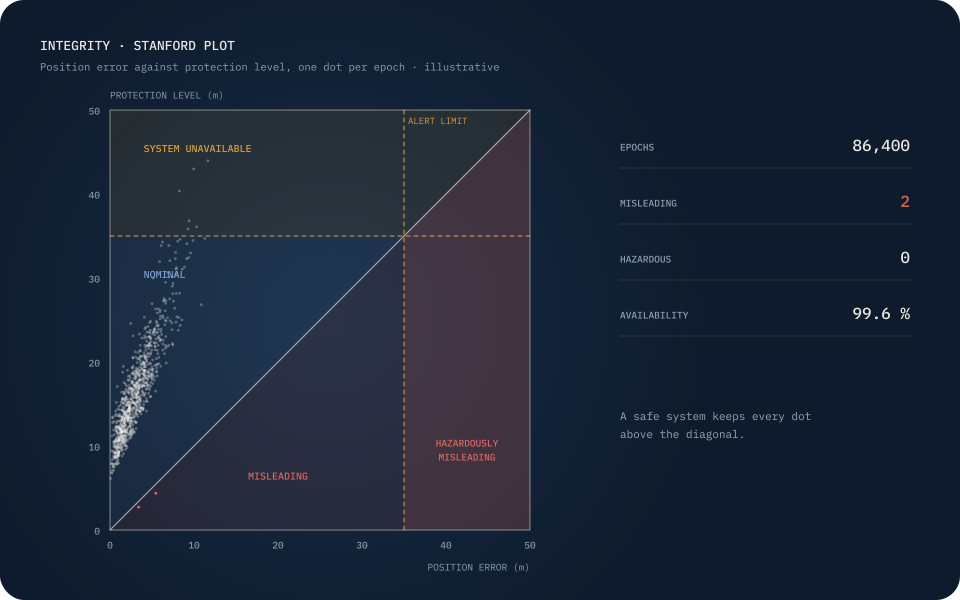
Integrity · 8 min read
How to show a system never understates its own error.
Coming soon
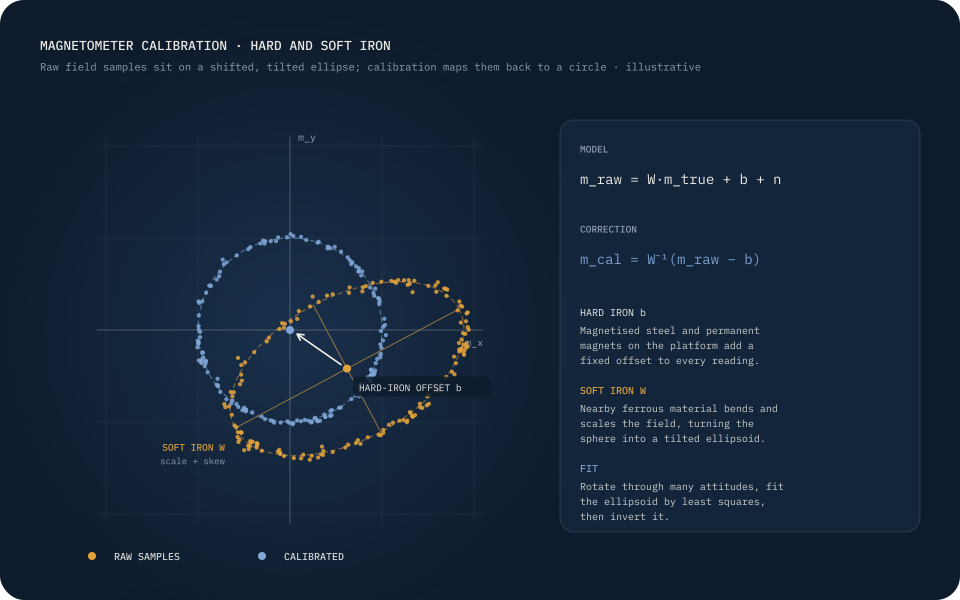
Magnetics · 6 min read
Hard iron, soft iron, and why the compass points at the motors.
Coming soon
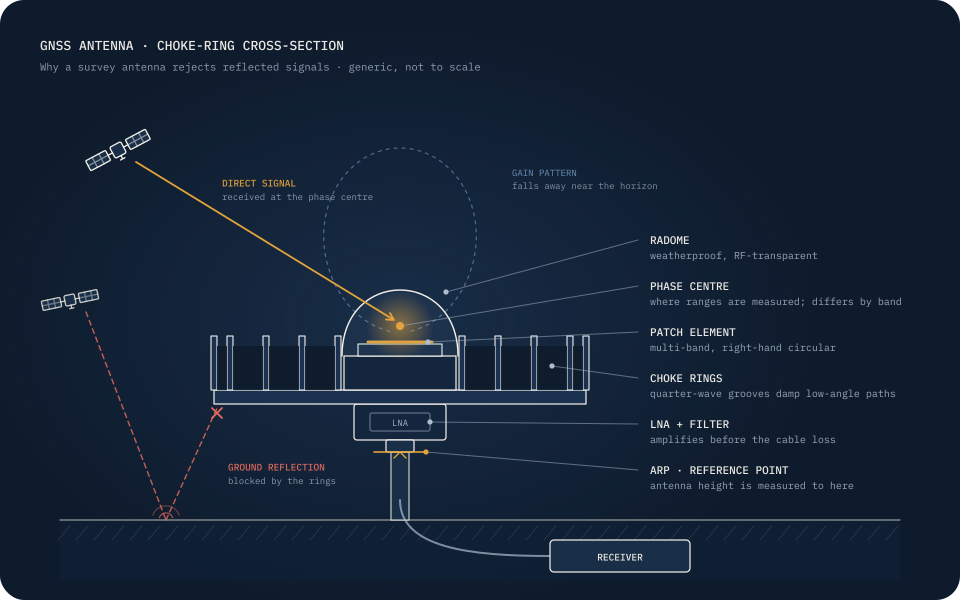
Antennas · 5 min read
Phase centres, choke rings and why the mount matters.
Coming soon