
LIVE DEMO
How far does a jammer reach?
See when a receiver loses lock as a jammer gets closer.
Integrate speed and heading along a route, add a heading bias or a speed error, and see how the position error grows with distance until a fix resets it.
LIVE DEMO · DEAD RECKONING
LOW ERROR
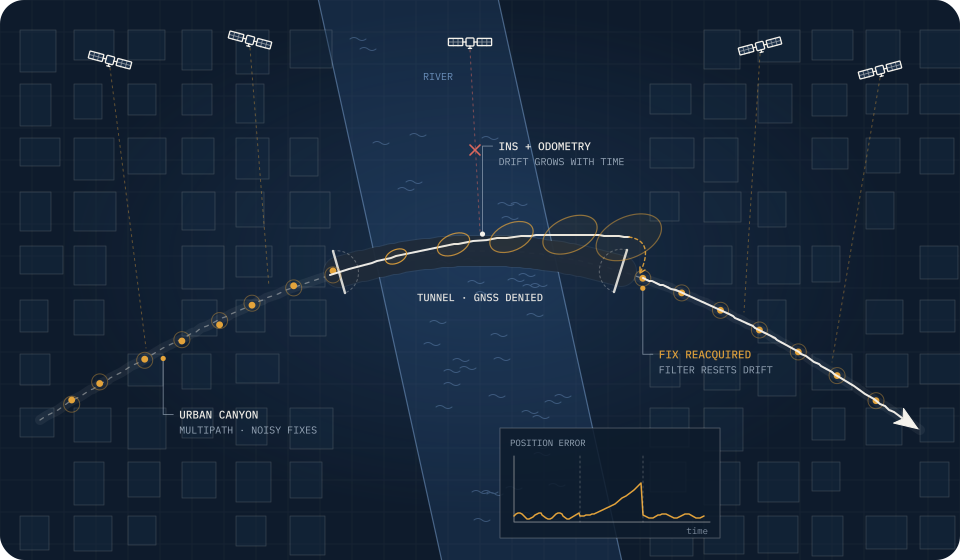
Illustrative
CONTROLS
Simulated, with illustrative figures. Runs in your browser; nothing is uploaded.
MORE
See when a receiver loses lock as a jammer gets closer.
Watch a position get dragged away, and which checks catch it.
See how long a clock stays on time once GNSS is gone.